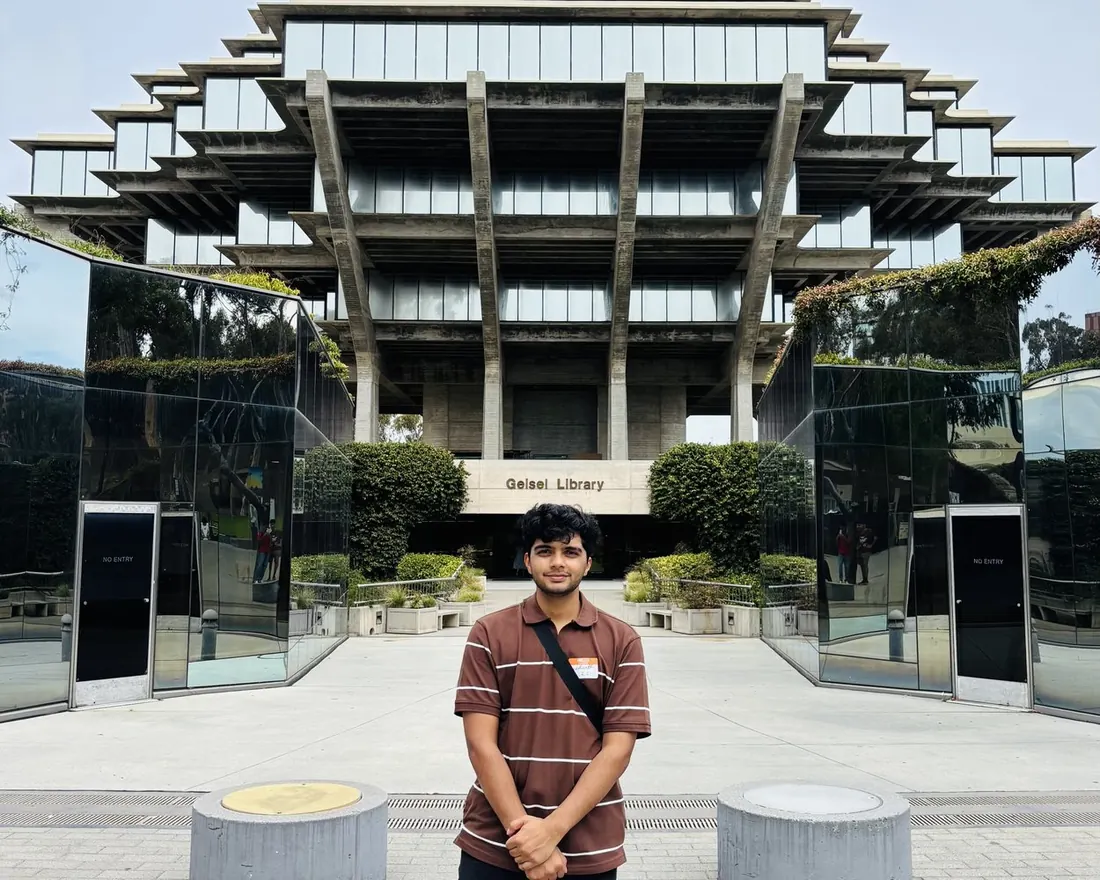
Siddharth Rama Sushil in front of Geisel Library, UC San Diego

Siddharth Rama Sushil

Robotics Software | Computer Vision | Deep Learning

I build perception, SLAM and robot-learning software that holds up on real hardware, from warehouse robots to dexterous hands. M.S. ECE at UC San Diego.

About Me

I'm a robotics software engineer and M.S. student at UC San Diego, specializing in Intelligent Systems, Robotics & Control. I've shipped perception and SLAM systems for warehouse robots at Addverb, built the layer that turns vision-language-model plans into robot skills at Amazon Robotics, and work on sim-to-real dexterous manipulation at UCSD's ARClab.

Geometry-grounded methods where reliability matters, learned policies where generalization matters.

University of California, San Diego

M.S. Electrical & Computer Engineering

Sep 2025 – Present

IIIT Jabalpur

B.Tech Mechanical Engineering

2019 – 2023 · Top 5% of batch

Experience

Amazon Robotics

Software Development Engineer Intern

Jun 2026 – Sep 2026

Agentic Robotics Orchestration

Designed and shipped the production C++ library that validates, dispatches and tracks the robot skills a vision-language model plans, with non-blocking ROS 2 execution. Fault-injection tests over DDS caught a crash bug before release, and with the V&V team I brought up a hardware-in-the-loop bench on the robot's ARM64 edge computer.

Agentic Loop Prototype

The agentic loop running on a Unitree G1 humanoid. The robot sees the table through its head camera and sends the image to a vision-language model. The model decides the next step, here picking up the cup, and calls one of the robot's skills to do it. When the skill finishes, the result goes back to the model, and it plans the step after that.
Addverb Technologies

Robotics Engineer

Aug 2023 – Jul 2025

Object Recognition & 6-DoF Pose Estimation

Lead architect of the perception stack for production robots, from detection through pose refinement, running on edge hardware. A self-calibrating camera held ±2 mm accuracy by correcting for structural droop.

Visual–Inertial SLAM Diagnostics

A real-time ORB-SLAM health indicator and debugging portal cut field debug time by 40%; a Kalman-filter fusion module bridged localization gaps between floor barcodes.

Semantic Segmentation & Scene Understanding

Compact, quantized models segment SKUs, chargers and conveyors; linking scene understanding with error logs made rare failures 45% faster to debug.

Simulation Fidelity

Sensor noise, IMU bias, network latency and domain randomization in simulation, so software validated in sim held up on real robots.

Deployment & DevOps

Dockerized the ROS stack with CI/CD that ships images to robots on push, and led on-site deployments with Siemens, ISITEC and Adidas.

UC San Diego

Student Researcher, ARClab · Advisor: Prof. Michael Yip

Sep 2025 – Present

Sim-to-Real Dexterous Manipulation

Training multi-fingered grasping policies in NVIDIA Isaac Sim with a teacher-student framework aimed at zero-shot sim-to-real transfer, using density-based and safety curricula for collision-aware grasping.

Defence Research and Development Organisation

Research Intern

Jan 2023 – Jul 2023

Infrared Small Target Detection

CNN-based detection of small infrared targets under low signal-to-noise ratio, with custom denoising, pixel-level annotated datasets and validation on edge hardware.

Featured Projects

SmolVAM: Robot Control with Small Video Action Models

A 0.7B video model, LoRA-tuned on ~0.1% of its weights, imagines future frames; a flow-matching decoder turns them into actions. 60% success on Cube Stack with a Franka arm.

LoRA · Flow Matching · VideoMAE · MuJoCo

Robust ORB-SLAM Pipeline

Adaptive CLAHE and guided filtering, with optional IMU-guided Wiener deblurring, in front of ORB-SLAM3. In glare-heavy corridors it cut time in degraded tracking by 23%, in real time.

ORB-SLAM3 · C++ · RealSense · Docker

Multimodal SLAM & State Estimation

LiDAR SLAM with ICP and GTSAM loop closure, visual–inertial SLAM with an EKF on SE(3), and IMU orientation tracking via quaternion kinematics.

LiDAR SLAM · GTSAM · EKF · VIO

Robust Plane Segmentation for 3D Pose Estimation

6-DoF pose of box faces from raw depth point clouds: RANSAC, clustering, MLS and a minimum-area rectangle. Under 0.2° mean normal error on synthetic benchmarks; tested with CI.

C++ · Point Clouds · Sensor Fusion

TidyBot: Home-Tidying Mobile Manipulator

A custom skid-steer robot with a 3-DOF arm that sweeps a two-room home with Nav2, collects five objects and brings them to a box, fully autonomous.

ROS 2 · Nav2 · Gazebo · URDF

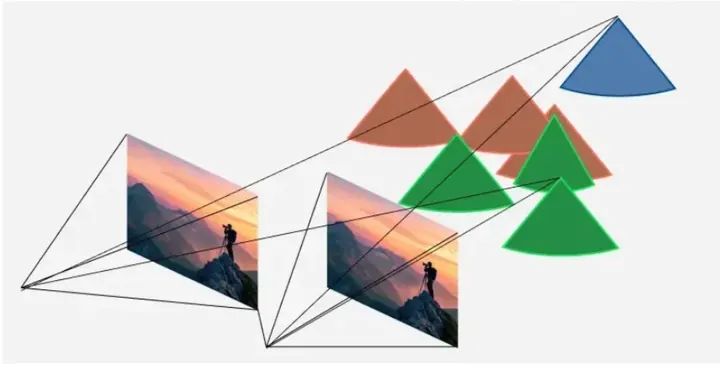
Visual Odometry Front End from Scratch

ORB features, essential-matrix initialization, triangulation and PnP tracking in C++17, with a test app for each stage.

C++17 · OpenCV · Eigen · SLAM

Epipolar Geometry Visualizer

Load two images and watch features, matches and epipolar lines update live as you tune the detector, matcher and RANSAC.

C++ · OpenCV · Two-View Geometry

Get In Touch

Always happy to talk robotics, research or collaborations. I usually reply within a day or two.

UC San Diego, where you'll find me most days.

Send a message

Goes straight to my inbox.